Nicolai Häni

Senior Member of Technical Staff · Lyte AI, Physical AI Labs

I build 3D perception systems that let machines understand the physical world. At Lyte, I work on state estimation and 3D reconstruction for robots.

Before Lyte, I spent 3.5 years at Magic Leap on Gaussian Splatting with integrated semantics for XR. For the last 1.5 years of that I was on assignment at Google, working on camera pose estimation and photorealistic reconstruction for indoor Immersive View in Google Maps. I received my Ph.D. from the University of Minnesota, advised by Volkan Isler, and earlier worked on robotic perception at Samsung AI Center and on photogrammetry at Pix4D.

Portrait of Nicolai Häni

Selected work

Indoor Immersive View in Google Maps

Google · Magic Leap · 2025 – 2026

Indoor Immersive View in Google Maps

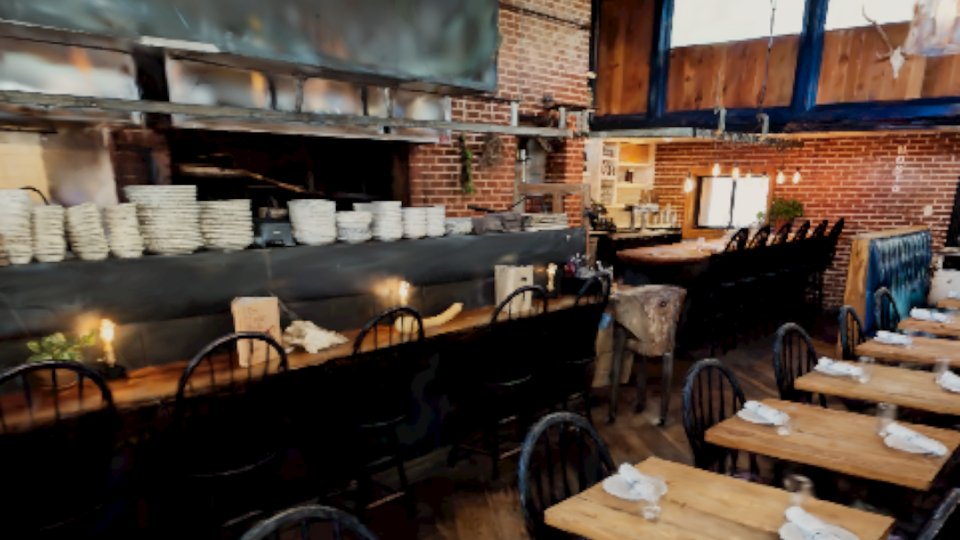
Camera pose estimation and Gaussian Splatting for photorealistic indoor 3D reconstruction. Built core parts of the pipeline that turns large indoor capture datasets into walkable 3D scenes in Google Maps. To try it, open Dai Due, Austin in the Google Maps app on a phone and tap the Immersive View photo.
Semantic Gaussian Splats for XR

Magic Leap · 2023 – 2024

Semantic Gaussian Splats for XR

Photorealistic 3D Gaussian Splatting reconstructions with integrated semantics, so objects in a scanned room can be selected and manipulated in XR. Includes open-set 3D instance segmentation.

University of Minnesota · 2020

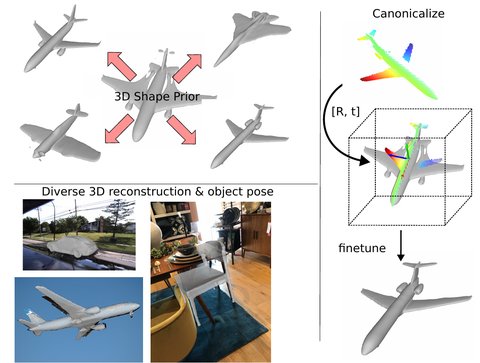
Continuous Object Representation Networks

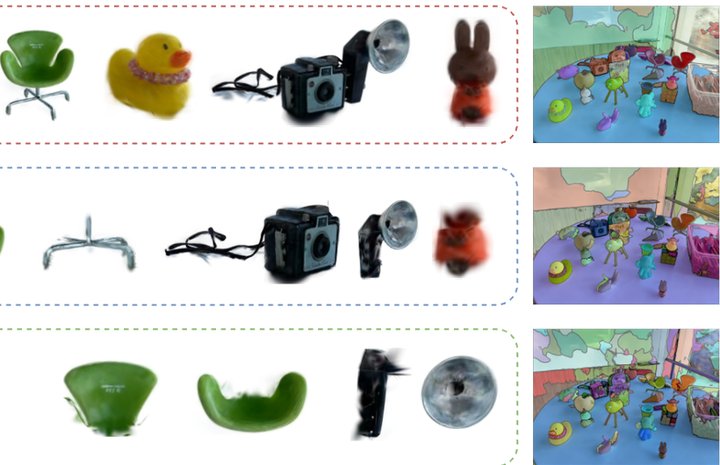
Novel view synthesis from a single image, trained without ground-truth 3D or target-view supervision. NeurIPS 2020.

Point Cloud Classification in PIX4Dmapper

Pix4D · 2016

Point Cloud Classification in PIX4Dmapper

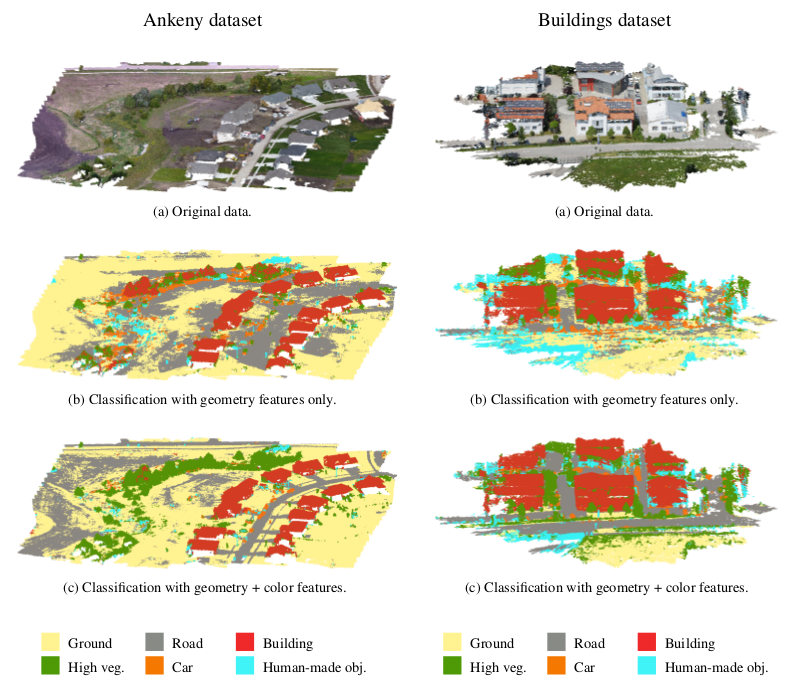
Classification of large aerial photogrammetry point clouds, shipped to thousands of surveying and mapping users. Received the ASPRS Talbert Abrams Award.

Experience

  1. 2026 – now
    Senior Member of Technical Staff, Lyte AI, Physical AI Labs · Sunnyvale, CA

    Perception for robots — state estimation and 3D reconstruction.

  2. 2025 – 2026
    Senior Computer Vision Researcher, on assignment at Google, Magic Leap · Sunnyvale, CA

    Camera pose estimation and Gaussian Splatting for indoor Immersive View in Google Maps.

  3. 2023 – 2024
    Senior Computer Vision Researcher, Magic Leap · Sunnyvale, CA

    Real-time pose estimation, Gaussian Splatting and open-set 3D instance segmentation for XR.

  4. 2021 – 2022
    Research Intern, Samsung AI Center · New York, NY

    3D detection, segmentation and reconstruction for robotic grasping.

  5. 2017 – 2023
    Ph.D. in Computer Science and Engineering, University of Minnesota · Minneapolis, MN

    Advised by Volkan Isler. Novel view synthesis, 3D reconstruction, agricultural robotics.

  6. 2015 – 2017
    Software Engineer, Pix4D · Lausanne, Switzerland

    Shipped 3D point cloud and sky-pixel classification in PIX4Dmapper.

  7. 2009 – 2015
    B.Sc. in Mechatronics, M.Sc. in Engineering, Zurich University of Applied Sciences · Winterthur, Switzerland

Publications

Lifting by Gaussians: A Simple, Fast and Flexible Method for 3D Instance Segmentation

Lifting by Gaussians: A Simple, Fast and Flexible Method for 3D Instance Segmentation

Rohan Chacko, Nicolai Häni, Eldar Khaliullin, Lin Sun, Douglas Lee

IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2025

Category-Level Global Camera Pose Estimation with Multi-Hypothesis Point Cloud Correspondences

Category-Level Global Camera Pose Estimation with Multi-Hypothesis Point Cloud Correspondences

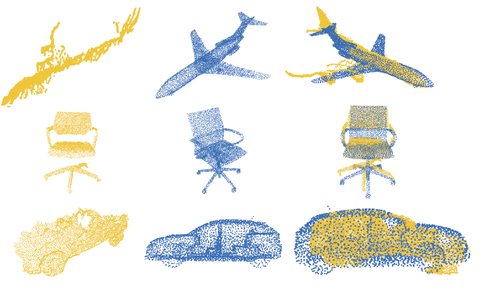
Jun-Jee Chao, Selim Engin, Nicolai Häni, Volkan Isler

IEEE International Conference on Robotics and Automation (ICRA), 2023

Multi-Step Recurrent Q-Learning for Robotic Velcro Peeling

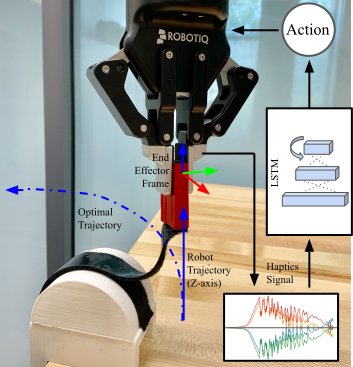
Multi-Step Recurrent Q-Learning for Robotic Velcro Peeling

Jiacheng Yuan, Nicolai Häni, Volkan Isler

IEEE International Conference on Robotics and Automation (ICRA), 2021

Continuous Object Representation Networks: Novel View Synthesis without Target View Supervision

Nicolai Häni, Selim Engin, Jun-Jee Chao, Volkan Isler

Advances in Neural Information Processing Systems (NeurIPS), 2020

MinneApple: A Benchmark Dataset for Apple Detection and Segmentation

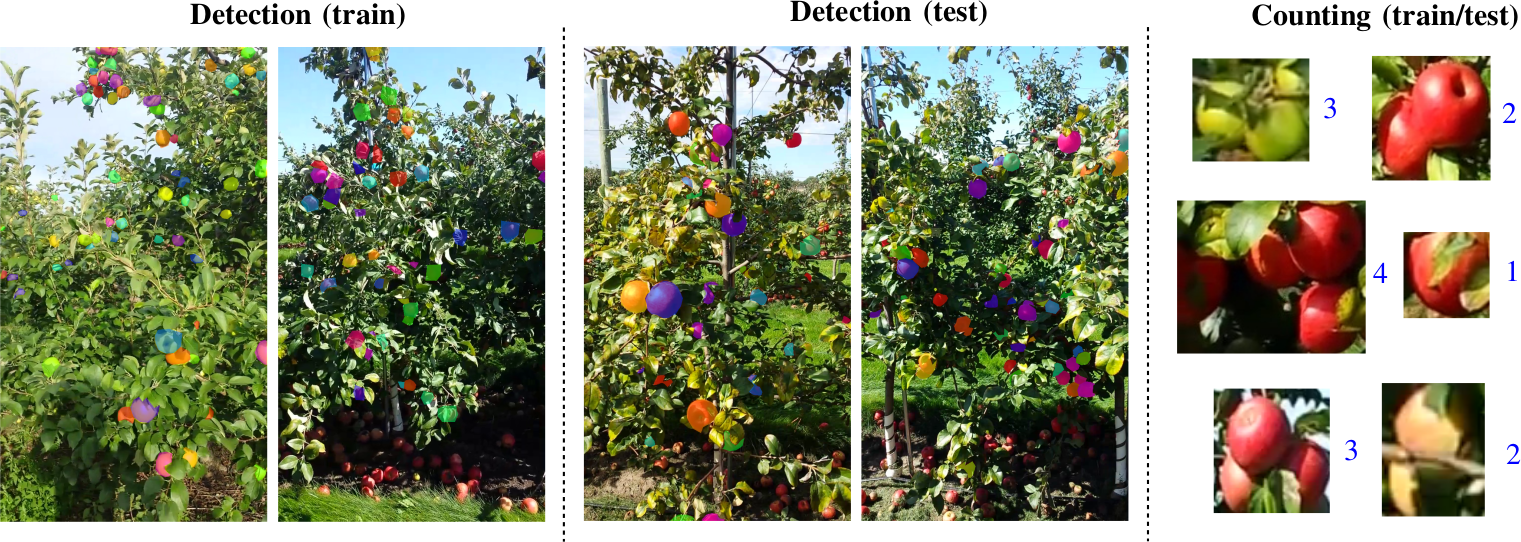
MinneApple: A Benchmark Dataset for Apple Detection and Segmentation

Nicolai Häni, Pravakar Roy, Volkan Isler

IEEE Robotics and Automation Letters (RA-L), 2020

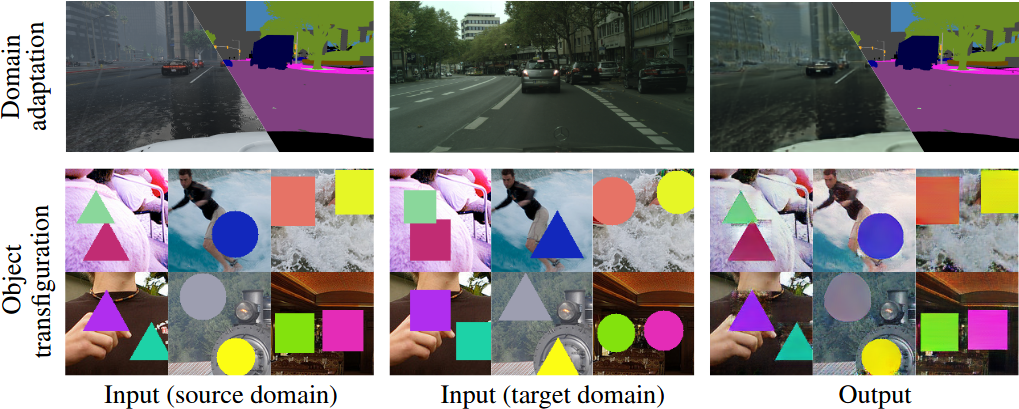
Semantics-Aware Image to Image Translation and Domain Transfer

Semantics-Aware Image to Image Translation and Domain Transfer

Pravakar Roy, Nicolai Häni, Jun-Jee Chao, Volkan Isler

arXiv preprint arXiv:1904.02203, 2019

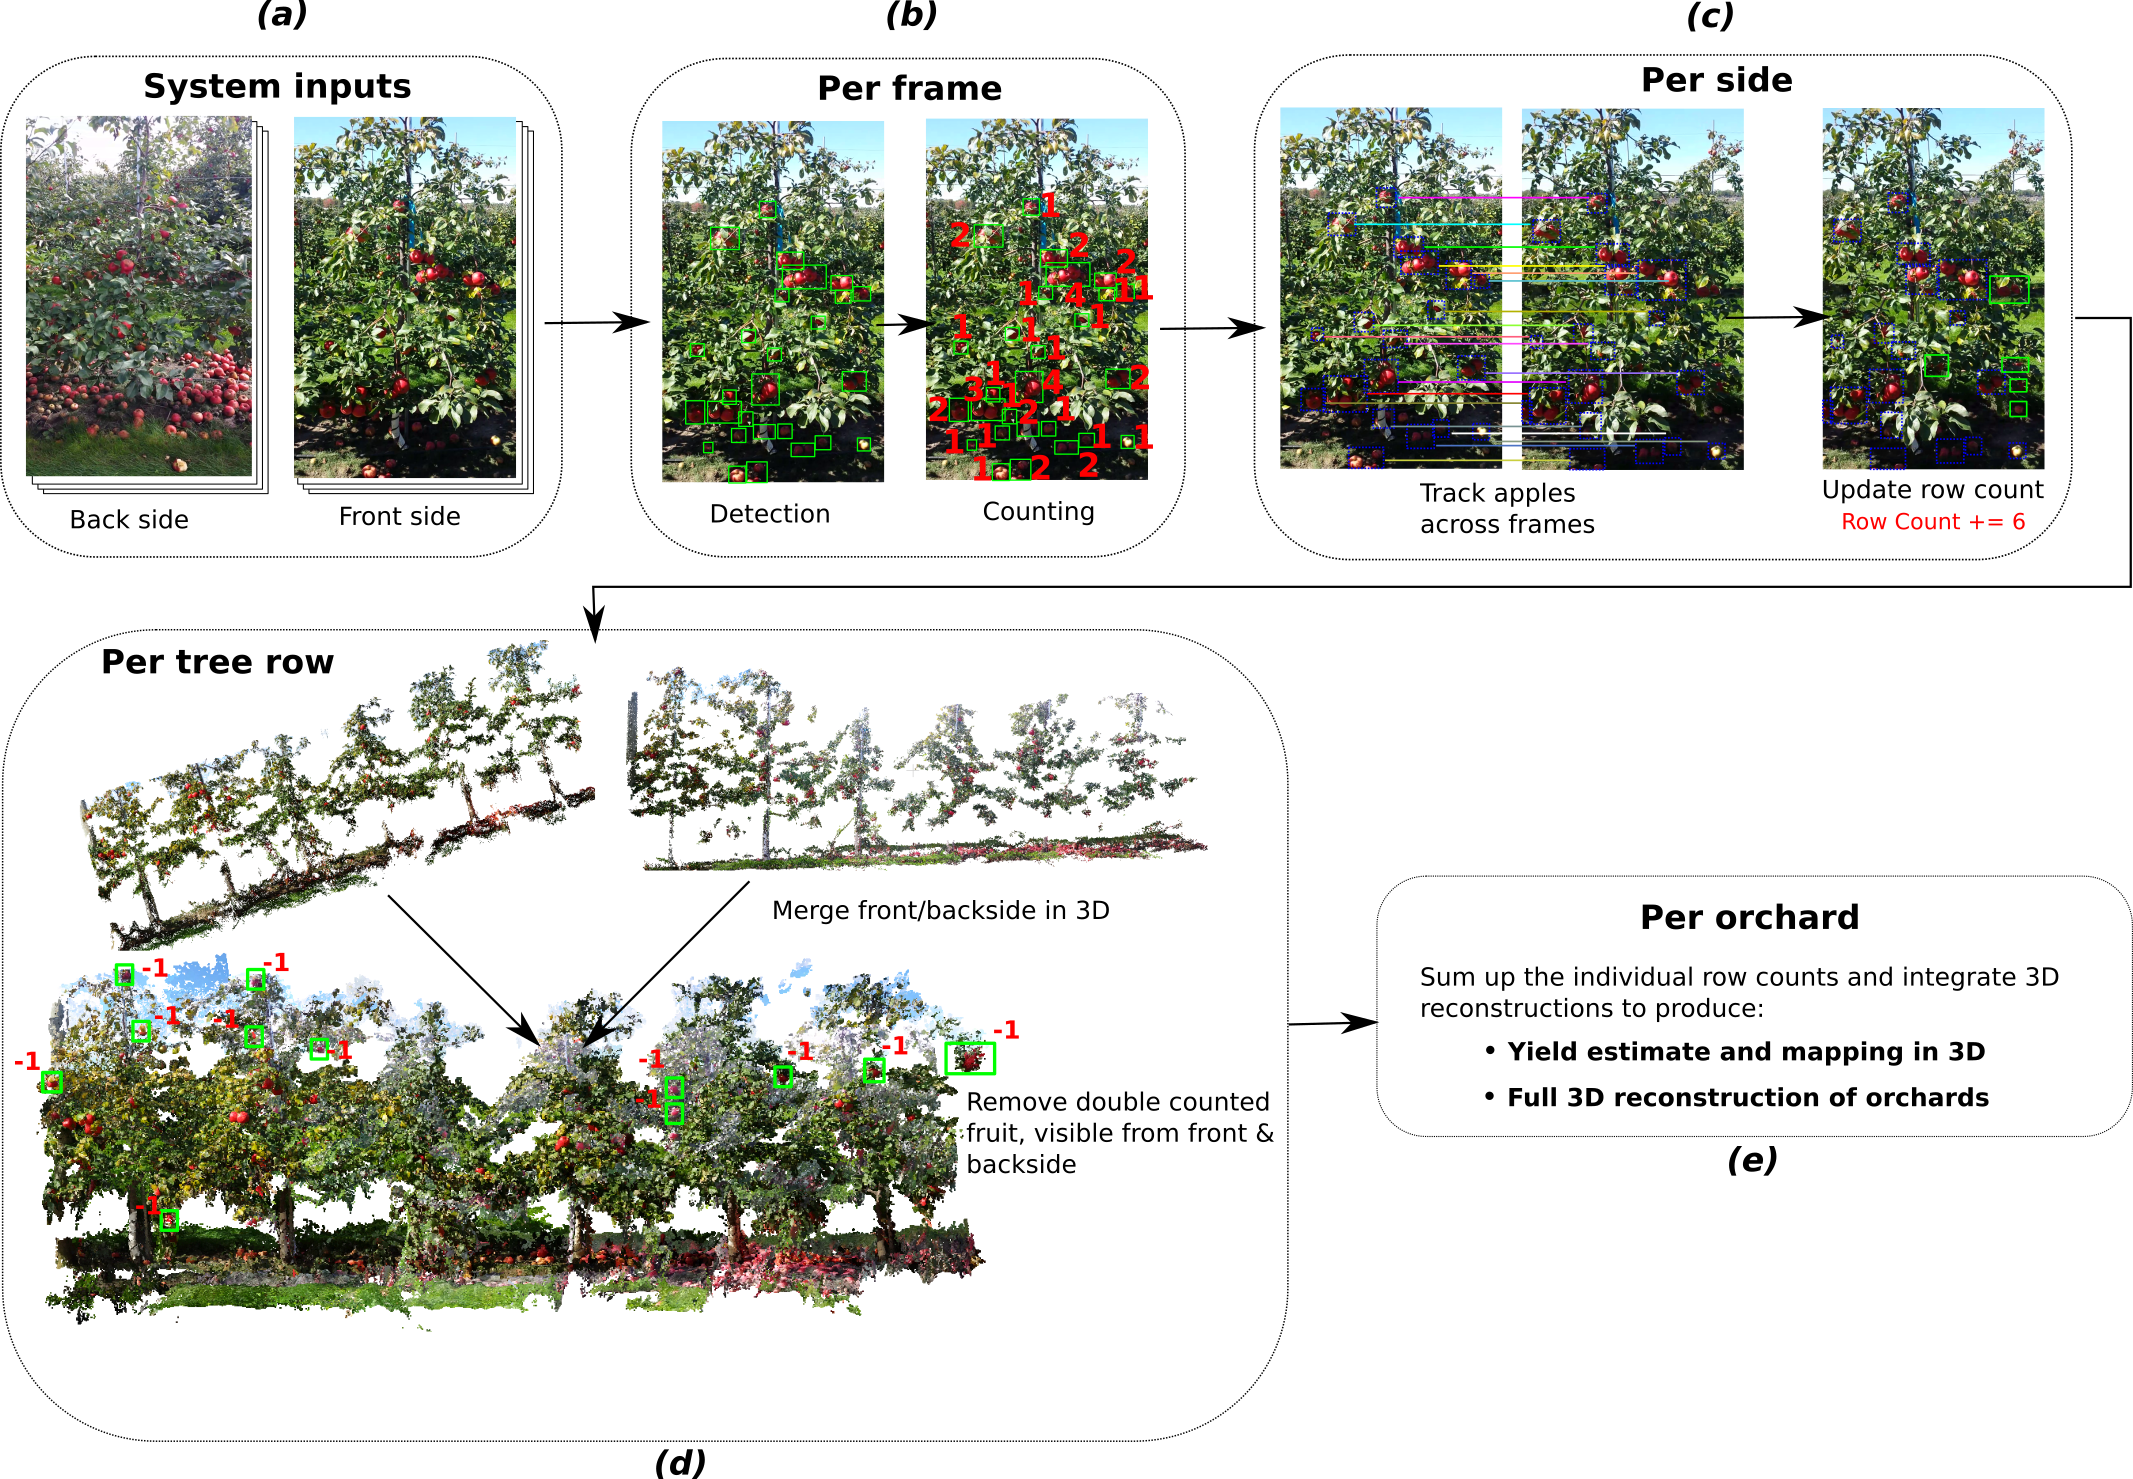
Apple Counting using Convolutional Neural Networks

Nicolai Häni, Pravakar Roy, Volkan Isler

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2018

Classification of Aerial Photogrammetric 3D Point Clouds

Classification of Aerial Photogrammetric 3D Point Clouds

Carlos Becker, Elena Rosinskaya, Nicolai Häni, Emmanuel d'Angelo, Christoph Strecha

Photogrammetric Engineering & Remote Sensing, 2018

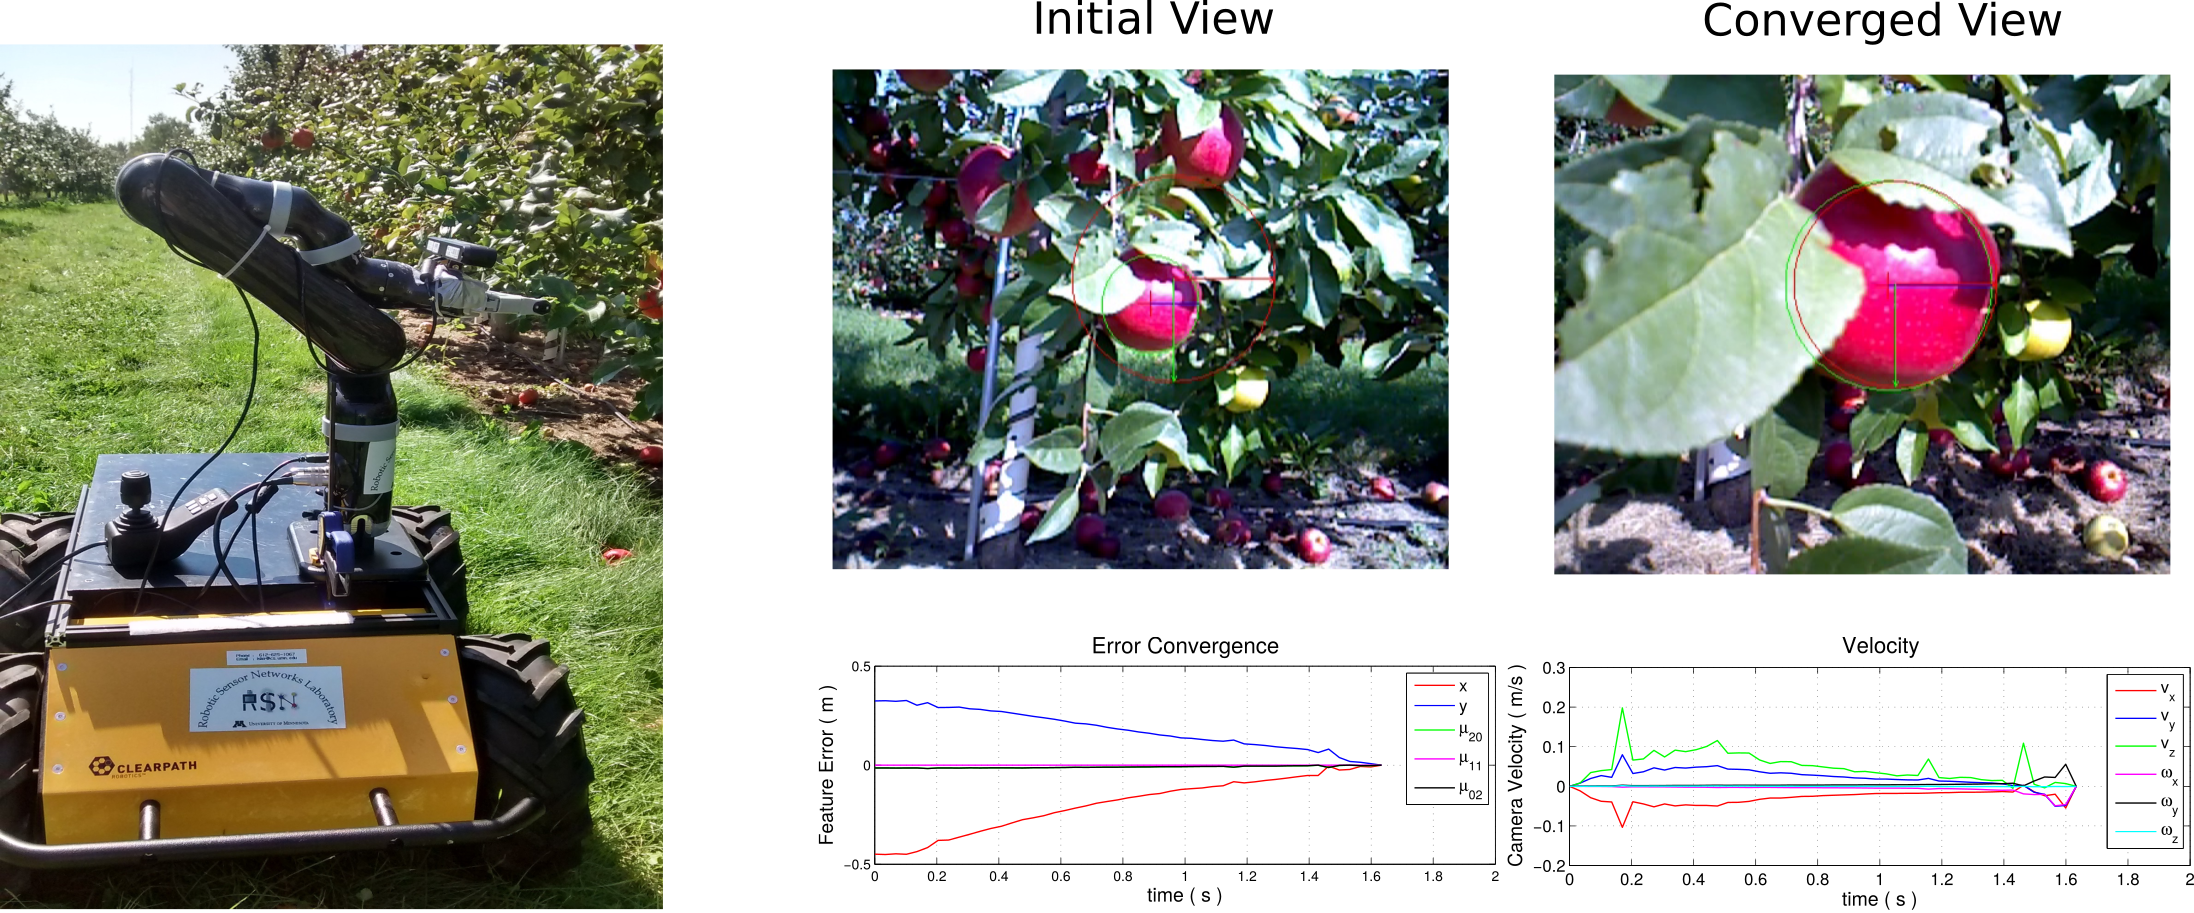
Visual Servoing in Orchard Settings

Visual Servoing in Orchard Settings

Nicolai Häni, Volkan Isler

IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2016

JMRR 2016

Cognitive Autonomous Catheters Operating in Dynamic Environments

Emmanuel Vander Poorten, et al.

Journal of Medical Robotics Research, 2016

Patents

Honors

  • Highlighted Reviewer, ICLR 2022
  • UMII MnDRIVE Graduate Assistantship, University of Minnesota, 2020
  • ASPRS Talbert Abrams Award, for point cloud classification, 2019
  • CSE Fellowship, University of Minnesota, 2017
  • Swiss Society for Automatic Control Master's Thesis Award, 2016

Service

Reviewer for CVPR, ICCV, ECCV, NeurIPS, ICLR, ICML, WACV, 3DV, ICRA and IROS, and for the journals RA-L, T-RO and JFR.